Videos
More on the lab's YouTube channel.
 Refreshing YCB for the Next Era of Embodied AI | Steve Xie × Prof. Sidd Srinivasa
 Long Range Navigator: Extending robot planning horizons beyond metric maps
 Lessons Learned from Designing and Evaluating a Robot-assisted Feeding System for Out-of-lab Use
 Multi-user, Out-of-lab Study of a Robot-assisted Feeding System for People with Motor Impairments
 In-home Deployment of a Robot-assisted Feeding System for People with Motor Impairments
 Data Efficient Behavior Cloning for Fine Manipulation via Continuity-based Corrective Labels
 Robot-Assisted Feeding: Recent Advances And Future Directions In The Personal Robotics Lab
 Physics-based Manipulation With and Around People: Siddhartha Srinivasa (Allen School)
 An Adaptive, Safe, and Portable Robot-Assisted Feeding System
 Ethan Gordon, Univ. of Washington: Tractably Adaptable Food Manipulation for Robot Assisted Feeding
 Demonstration: Towards General Single-Utensil Food Acquisition with Human-Informed Actions
 From Crowd Motion Prediction to Robot Navigation in Crowds [IROS 2023]
 PuSHR: A Multirobot System Nonprehensile Rearrangement [IROS 2023]
 Unintended Failures of Robot-Assisted Feeding in Social Contexts
 Design Principles for Robot-Assisted Feeding in Social Contexts
 Taylor Kessler Faulkner - Enabling Robots to Adapt to and Learn from Real People
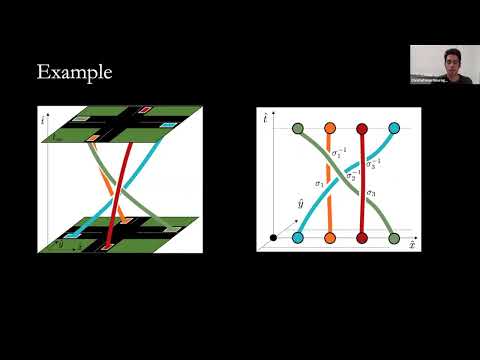 Analyzing Multiagent Interactions in Traffic Scenes via Topological Braids
 Winding Through: Crowd Navigation via Topological Invariance
 Analyzing Multiagent Interactions in Traffic Scenes via Topological Braids [ICRA 2022]
 Not All Who Wander Are Lost: A Localization-Free System for In-the-Wild Mobile Robot Deployments
 [CS 6751] Interactive QnA - Siddhartha Srinivasa (University of Washington / Amazon Robotics)
 Not All Who Wander Are Lost: A Localization-Free System for In-The-Wild Mobile Robot Deployments
 Q&A with Sidd Srinivasa, director of Amazon Robotics AI
 ICRA 2021 Curiosity Workshop: Siddhartha Srinivasa
 RSS 2021, Spotlight Talk 25: Modeling Human Helpfulness with Individual and Contextual Factors...
 Meet a Roboticist | Small Meets Big | KiwiCo
 Learning for Caregiving Robots - ICRA 2021 Workshop
 Grasping with Chopsticks | Model Free Imitation Learning for Fine Manipulation Challenge
 Chris Mavrogiannis
 Chris Mavrogiannis: Leveraging structure for autonomous robot navigation in multiagent human spaces
 Combating covariate shift ⚔️ for fine manipulation 🥢
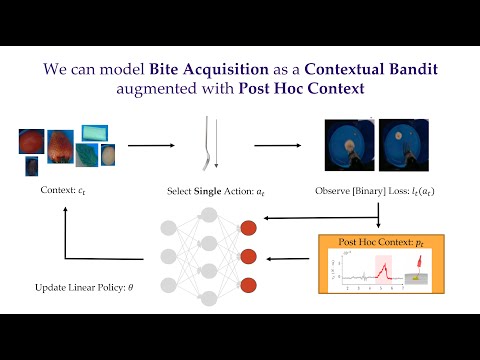 Leveraging Post Hoc Context for Faster Learning in Bandit Settings applied to Robot-Assisted Feeding
 Chopsticks Robot: The Beginning of a Journey
 Adaptive Robot-Assisted Feeding: An Online Learning Framework for Acquiring Previously Unseen Food
 "New Connections between Motion Planning and Machine Learning" - Sidd Srinivasa
 What Should I Work On?
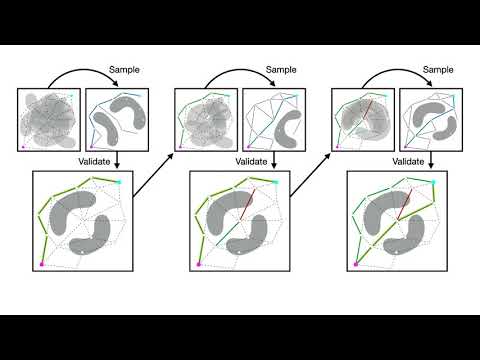 Posterior Sampling for Anytime Motion Planning (ICRA 2020)
 Is More Autonomy Always Better?: Exploring Preferences of Users with Mobility Impairments in ...
 Evaluating an Assistive-Feeding Robot with Users with Mobility Limitations
 MuSHR: Multiagent System for NonHolonomic Racing
 Online Learning for Food Manipulation
 The Blindfolded Robot: A Bayesian Approach to Planning with Contact Feedback
 Generalizing Skewering Strategies across Food Items
 Bite Acquisition with Tactile Sensing
 ICAPS 2018: Aditya Mandalika on "Lazy Receding Horizon A* for Efficient Path Planning in ..."
 ICAPS 2018: Oren Salzman on "The Provable Virtue of Laziness in Motion Planning"
 Towards Robotic Feeding: Role of Haptics in Fork-based Food Manipulation
 Transfer depends on Acquisition: Analyzing Manipulation Strategies for Robotic Feeding
 Autonomous Robot Feeding with Assistive Dexterous Arm (ADA)
 Archive: Building a Robot Butler: Towards Fluent Human Robot Interaction
 ICAPS 2017: Efficient motion planning for problems lacking optimal substructure
 Automated Feeding with Assistive Robot Arm
 Nonprehensile Whole Arm Rearrangement Planning on Physics Manifolds
 RI Seminar: Henny Admoni: Toward Natural Interactions With Assistive Robots
 RI Seminar: Sidd Srinivasa: Robotic Manipulation...
 Eating Assistance Through Shared Autonomy with An Intelligent Robotic Arm
 UW CSE Colloquia: Siddhartha Srinivasa (CMU)
 Distance Metrics and Algorithms for Task Space Path Optimization
 On-line human-robot cooperation
 Functional Gradient Motion Planning in Reproducing Kernel Hilbert Spaces
 Formation-Based Multi-Robot Coverage
 Siddhartha Srinivasa : Manipulation, Robots Performing Complex Tasks
 Convergent Planning
 UW CSE Robotics: Henny Admoni, "Recognizing Human Intent for Assistive Robotics"
 HERB Pours a Glass of Water
 HERB Stacks Cups
 HERB Sorts Colored Blocks
 Learning Trajectory Constraints from Demonstrations
 An Analysis of Deceptive Robot Motion
 Automated Dining via an Intelligent Robot Arm
 or_rviz Viewer Plugin
 Robust Push Planning Under Uncertainty
 or_ompl - OpenRAVE bindings for OMPL
 Reconfiguration planning using physics models
 17:50 - 18:20 Invited Talk: Siddhartha Srinivasa, CMU - Feedback-driven Physics-based Manipulation
 HERB ProCam Test
 Siddhartha Srinivasa at the FIRST Robotics Competition - Greater Pittsburgh Regional 2014
 ADA autonomous manipulation
 HERB-Drama: Trailer 1 for "All in the Timing"
 Deliberate Delays During Robot-To-Human Handovers Improve Compliance With Gaze Communication
 Pose Estimation for Contact Manipulation with Manifold Particle Filters
 HERB the Robot Stars in Oreo Video
 Object Search by Manipulation
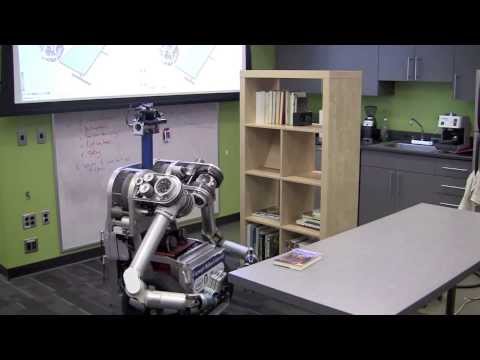 HERB manages a library
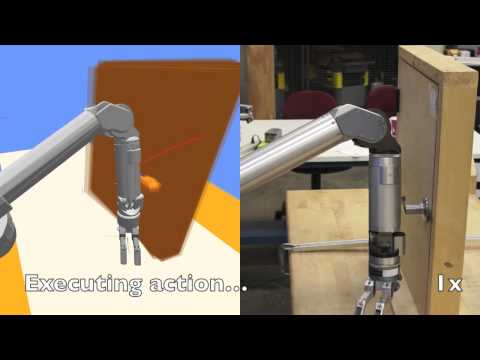 Efficient Touch Based Localization through Submodularity
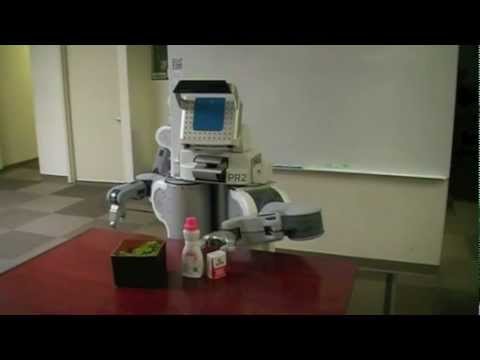 Physics-Based Grasp Planning through Clutter
 Robotiq Hand Tests
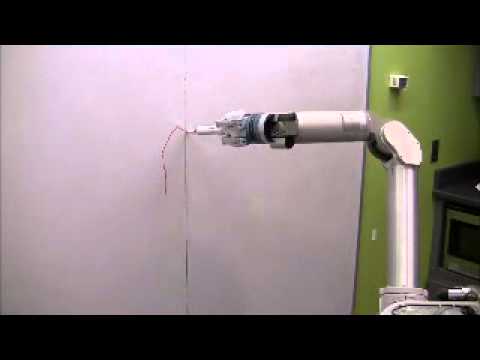 HERB Draws based on iPAD interface.
 The Tick bot project
 HerbSemifinal.wmv
 Solving Towers of Hanoi with HERB
 Robot Microwaves a Meal
 HERB Prepares a Meal
 Lifelong Robotic Object Discovery
 Rearrangement Planning using Pushing Actions
 Manipulation Planning with Goal Sets Using Constrained Trajectory Optimization
 Human Preferences for Robot-Human Hand-over Configurations
 Improving Fluency in Human-Robot Handovers
 Columbia Grasp Database
 The Story of HERB
 Push-grasping with HERB
 Addressing Cost-Space Chasms in Manipulation Planning
 HERB imitates Anca
 MOPED Object recognition and pose estimation in HD Video
 HERB clip from Rocketboom's "Technology and Innovation by Intel, Pittsburgh Labs"
 Grasp Synthesis in Cluttered Environments for Dexterous Hands
 Grasp Planning in Complex Scenes
 Pose-Constrained Whole-Body Planning using Task Space Region Chains
 Manipulation Planning on Constraint Manifolds
 Herb: Robot Butler
 HERB at Research @ Intel Day 2010
 HERB at Discovery Channel Canada
 Intel Pittsburgh Open House 2009
 People helping robots helping people
 Technology and Innovation by Intel, Pittsburgh Labs
 Efficient Multi-View Object Recognition and Pose Estimation
 3D Object Modeling from Sparse and Noisy Laser Data, Personal Robotics at Intel Labs Pittsburgh
 Pre-grasp object manipulation, Personal Robotics at Intel Labs Pittsburgh
 Multi-camera MOPED, Personal Robotics at Intel Labs Pittsburgh
 Manipulation Lab: Do What You Do by Eldridge Gravy & the Court Supreme
 The delivery robot
 Loading Cups in Dishrack
 Manipulation Planning with Door Opening
 Autonomous Manipulation (IRP2008)
 Intel Research / CMU - BiSpace planning
 CHOMP: Covariant Hamiltonian Optimization for Motion Planning